
Collective intelligence for physical AI.
Every machine will learn from all the others. Robots, drones and cameras from any maker will share what they understand about each place and every job done there.
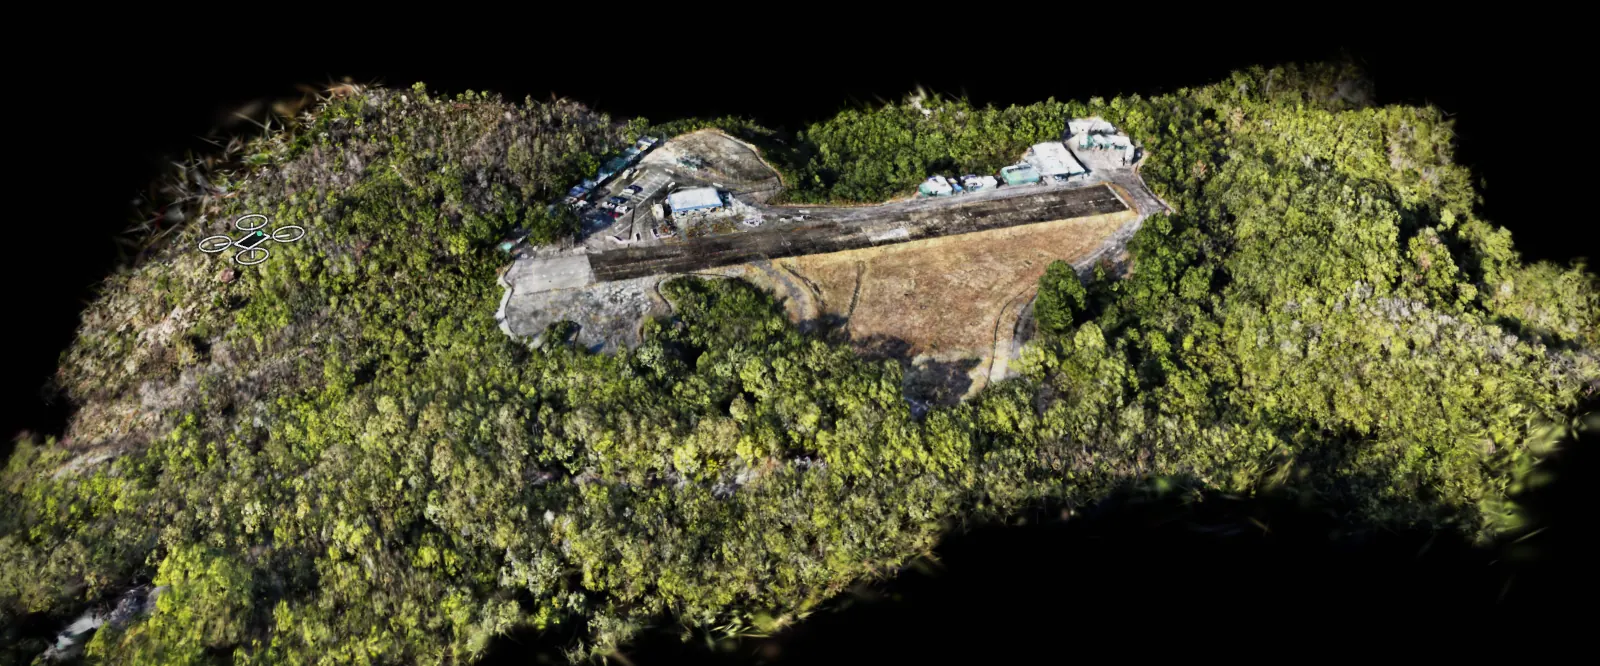
Today, bringing a hundred machines into one place means mapping it a hundred times.
A few robots take about a week to set up, and each new one starts from scratch instead of adding to what the others already know.
A drone maps a route once. Every drone after it will fly that route by its own camera, even with GPS jammed.
A robot new to an airport will start work on day one, on the map the other machines already built.
When one machine spots a spill, the others will know where it is and that one is already on it.
Every job will leave every machine a little smarter.
How it works
A machine will trust what another saw because it can check it.
It compares what its own camera sees with the shared map. A true position lines up; a false one breaks.
In each frame, left of the line is what the drone’s camera sees. Right of it is the shared map, seen from the position being checked.
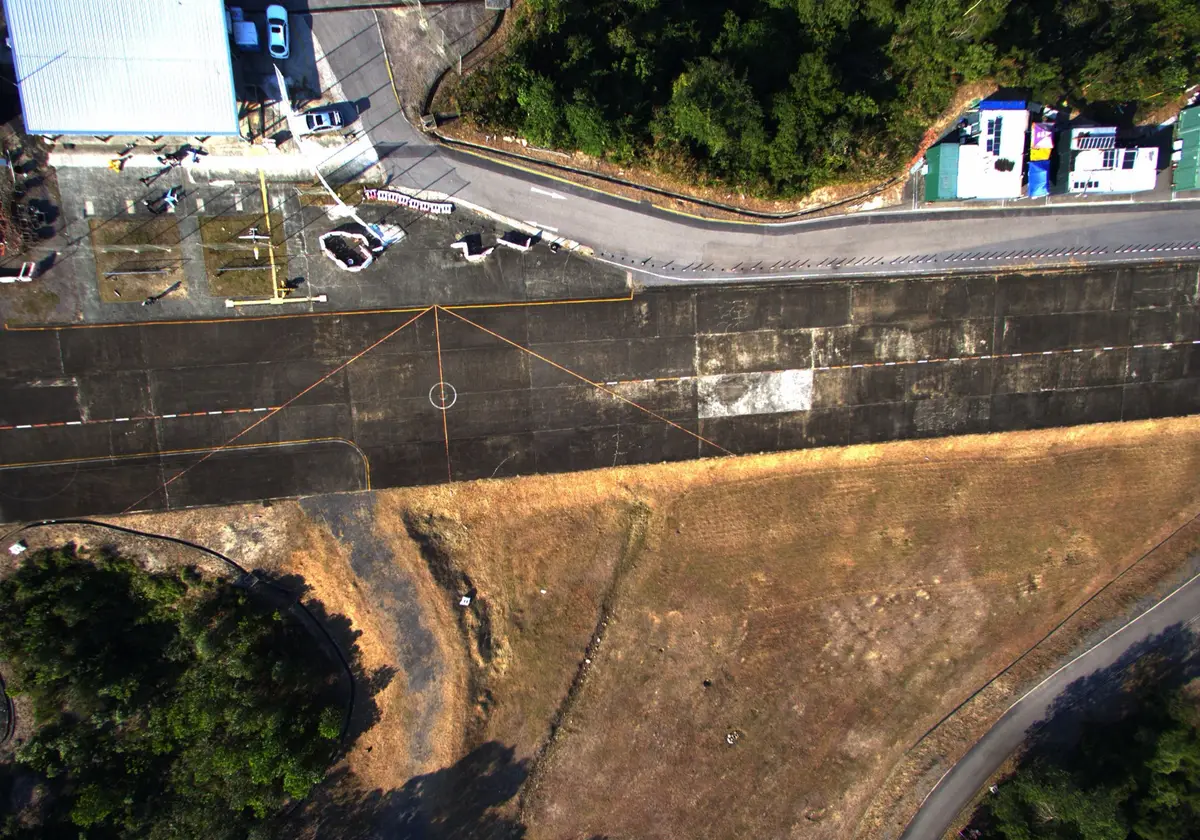
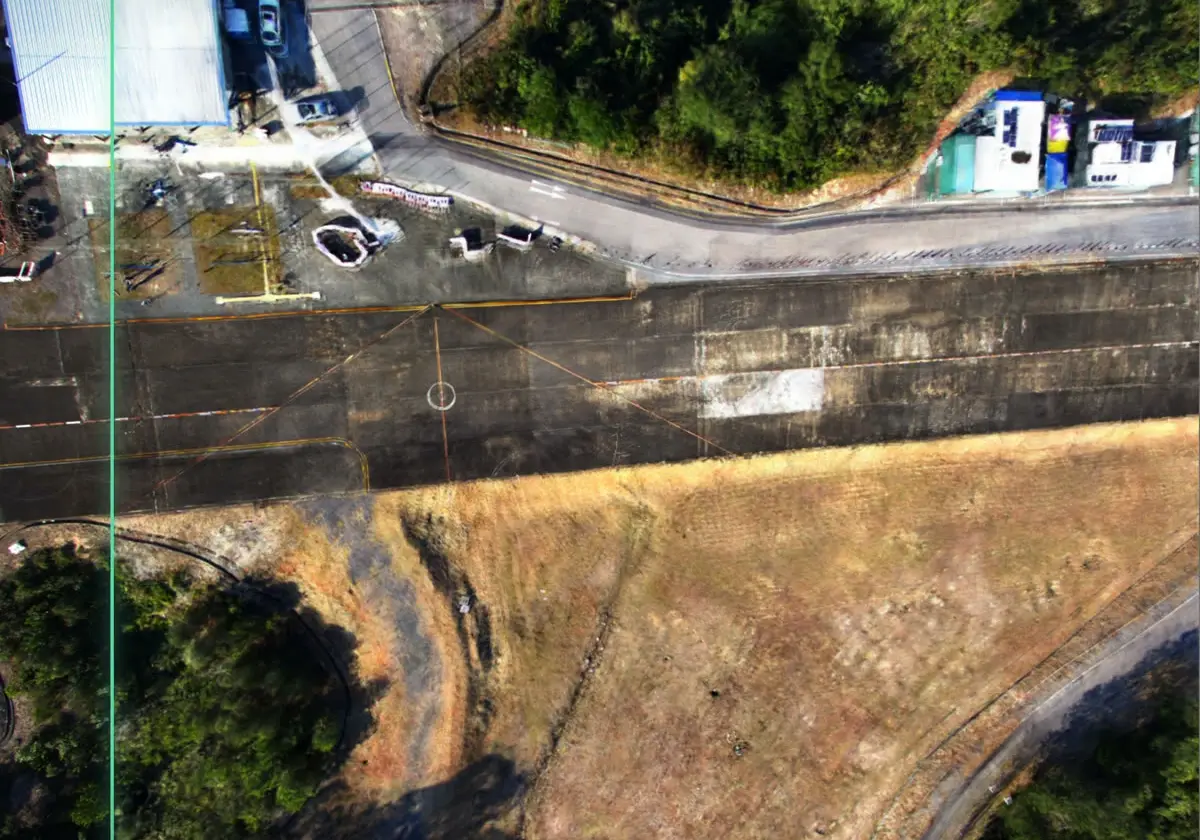
The map, seen from where the camera places the drone, lines up with what it sees.
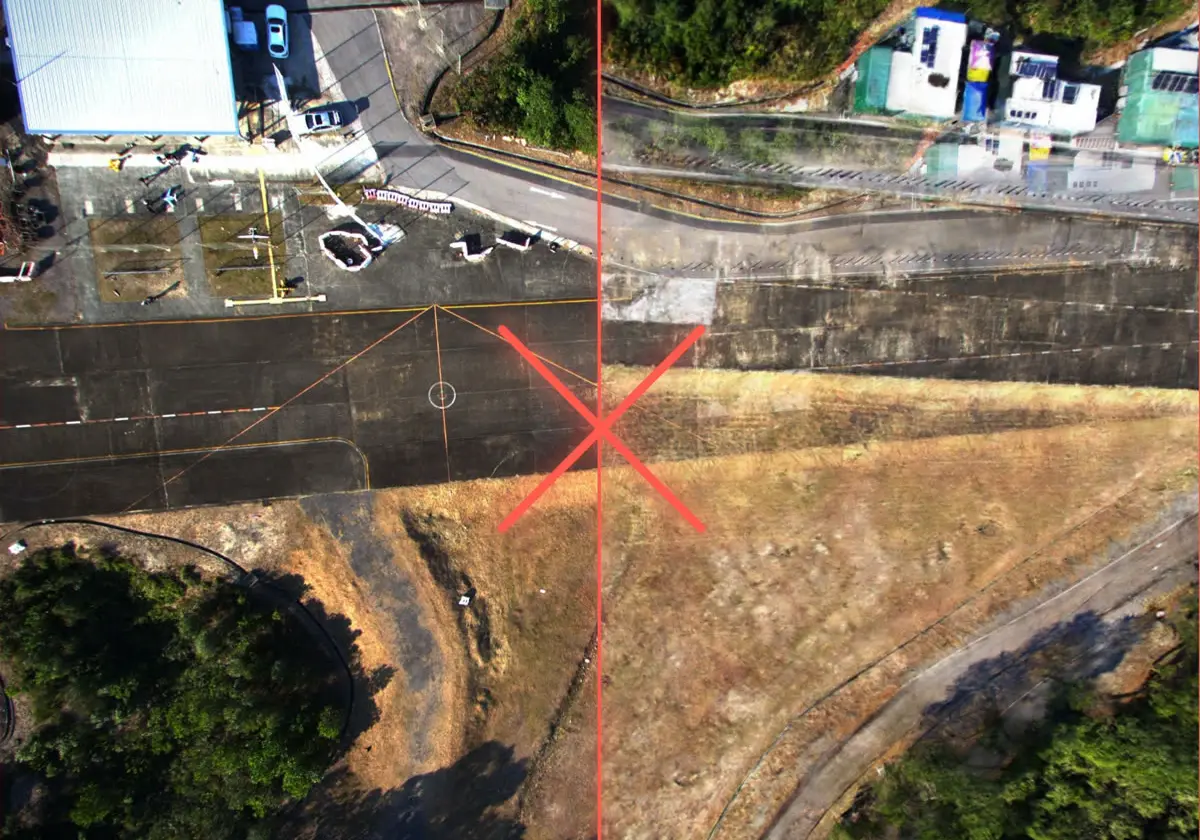
Seen from where the GPS says the drone is, the map breaks at the line. The fake is caught.
Why a public record
No maker can referee its rivals, so the record goes where none of them controls it.
The map stays with the owner of the place. Only a fingerprint of each check is kept on a public record that no single company can edit after the fact.
We’re starting with drones.
GPS can be jammed or faked. A drone that checks its position against the shared map won’t depend on it, and that same check is what every machine will need to trust another.
Founding team
 Luca TrevisaniComputer Science. Co-founded Augea. Superteam Brasil.
 Elijah YoungMechanical Engineering at MIT. MIT Media Lab. TSMC.
 Dhruvil ParikhMS Robotics, Northeastern. Drone software for NASA programs at GreenSight. Co-founder and CTO of AISafe.

Every machine will learn from all the others.
Building with robots or drones, investing, or want to join? Write to luca@colpero.com.